Move here.
Act there.
Real-time cross-continental teleoperation. Trained operators in India guide I2RT YAM robotic arms in Mexico with low latency and AR/VR spatial simulation.
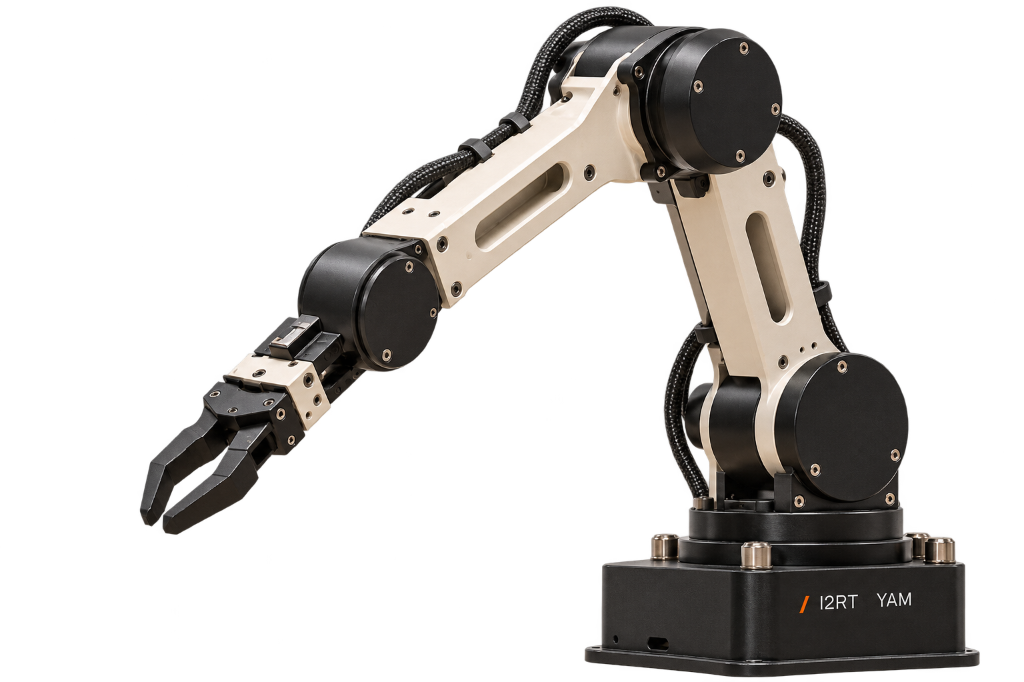
Meet the arm.
One operator. Two routes.
Physical distance does not mean operational compromise. Aktoria's proprietary network stack routes low-latency teleoperation packets directly between Indian operator hubs and client factories across Mexico.
As you scroll, this coordinate grid tilts to form the floor plane of the remote workcell in Monterrey.
See what the operator sees.
In AR and VR, remote operators in India do not merely watch video feeds: they operate within a real-time 3D reconstruction of the remote workspace, synchronized with sub-centimeter fiducial tracking.
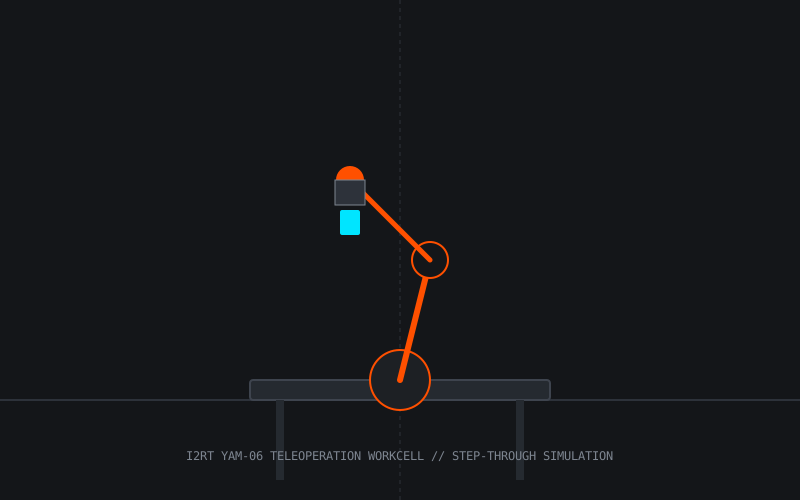
3D Workcell Simulation
Hardware accelerated WebGL is not available on this device. Showing illustrative step-through render.
I2RT YAM 6-DOF Manipulator
Six brushless direct-drive actuators with low-inertia carbon-fiber links allow rapid, precise trajectory tracking under operator guidance.
Pick. Move. Place.
Experience cross-continental teleoperation firsthand. Align the gripper, pinch the workpiece, and transfer it cleanly to the designated inspection zone.
Align Gripper
Center the gripper fingers directly over the machined workpiece.
Close & Pinch
Activate parallel linear clamp with calibrated 15 N force.
Move & Place
Transfer the piece to the destination zone and release.
Bring your workspace within reach.
Whether piloting I2RT YAM arms across Mexico or deploying teleoperated fleets globally from our San Francisco headquarters, Aktoria connects human dexterity with industrial robotics anywhere on Earth.